FT-WBC-Learning-Fault-Tolerant-Whole-Body-Control-for-Legged-Loco-Manipulation
FT-WBC: Learning Fault-Tolerant Whole-Body Control for Legged Loco-Manipulation
This repository hosts the official implementation and project materials for FT-WBC: Learning Fault-Tolerant Whole-Body Control for Legged Loco-Manipulation.
Project Page: https://ft-wbc.github.io/
FT-WBC is a fault-tolerant whole-body control framework for legged loco-manipulation under actuator failures. The goal is to improve the robustness of legged manipulators when lower-limb actuator faults occur, enabling stable locomotion and manipulation through fault-aware policy adaptation.
Overview
Legged manipulators combine quadruped mobility with robotic arm manipulation. However, actuator failures can severely affect balance, reachable workspace, and task success.
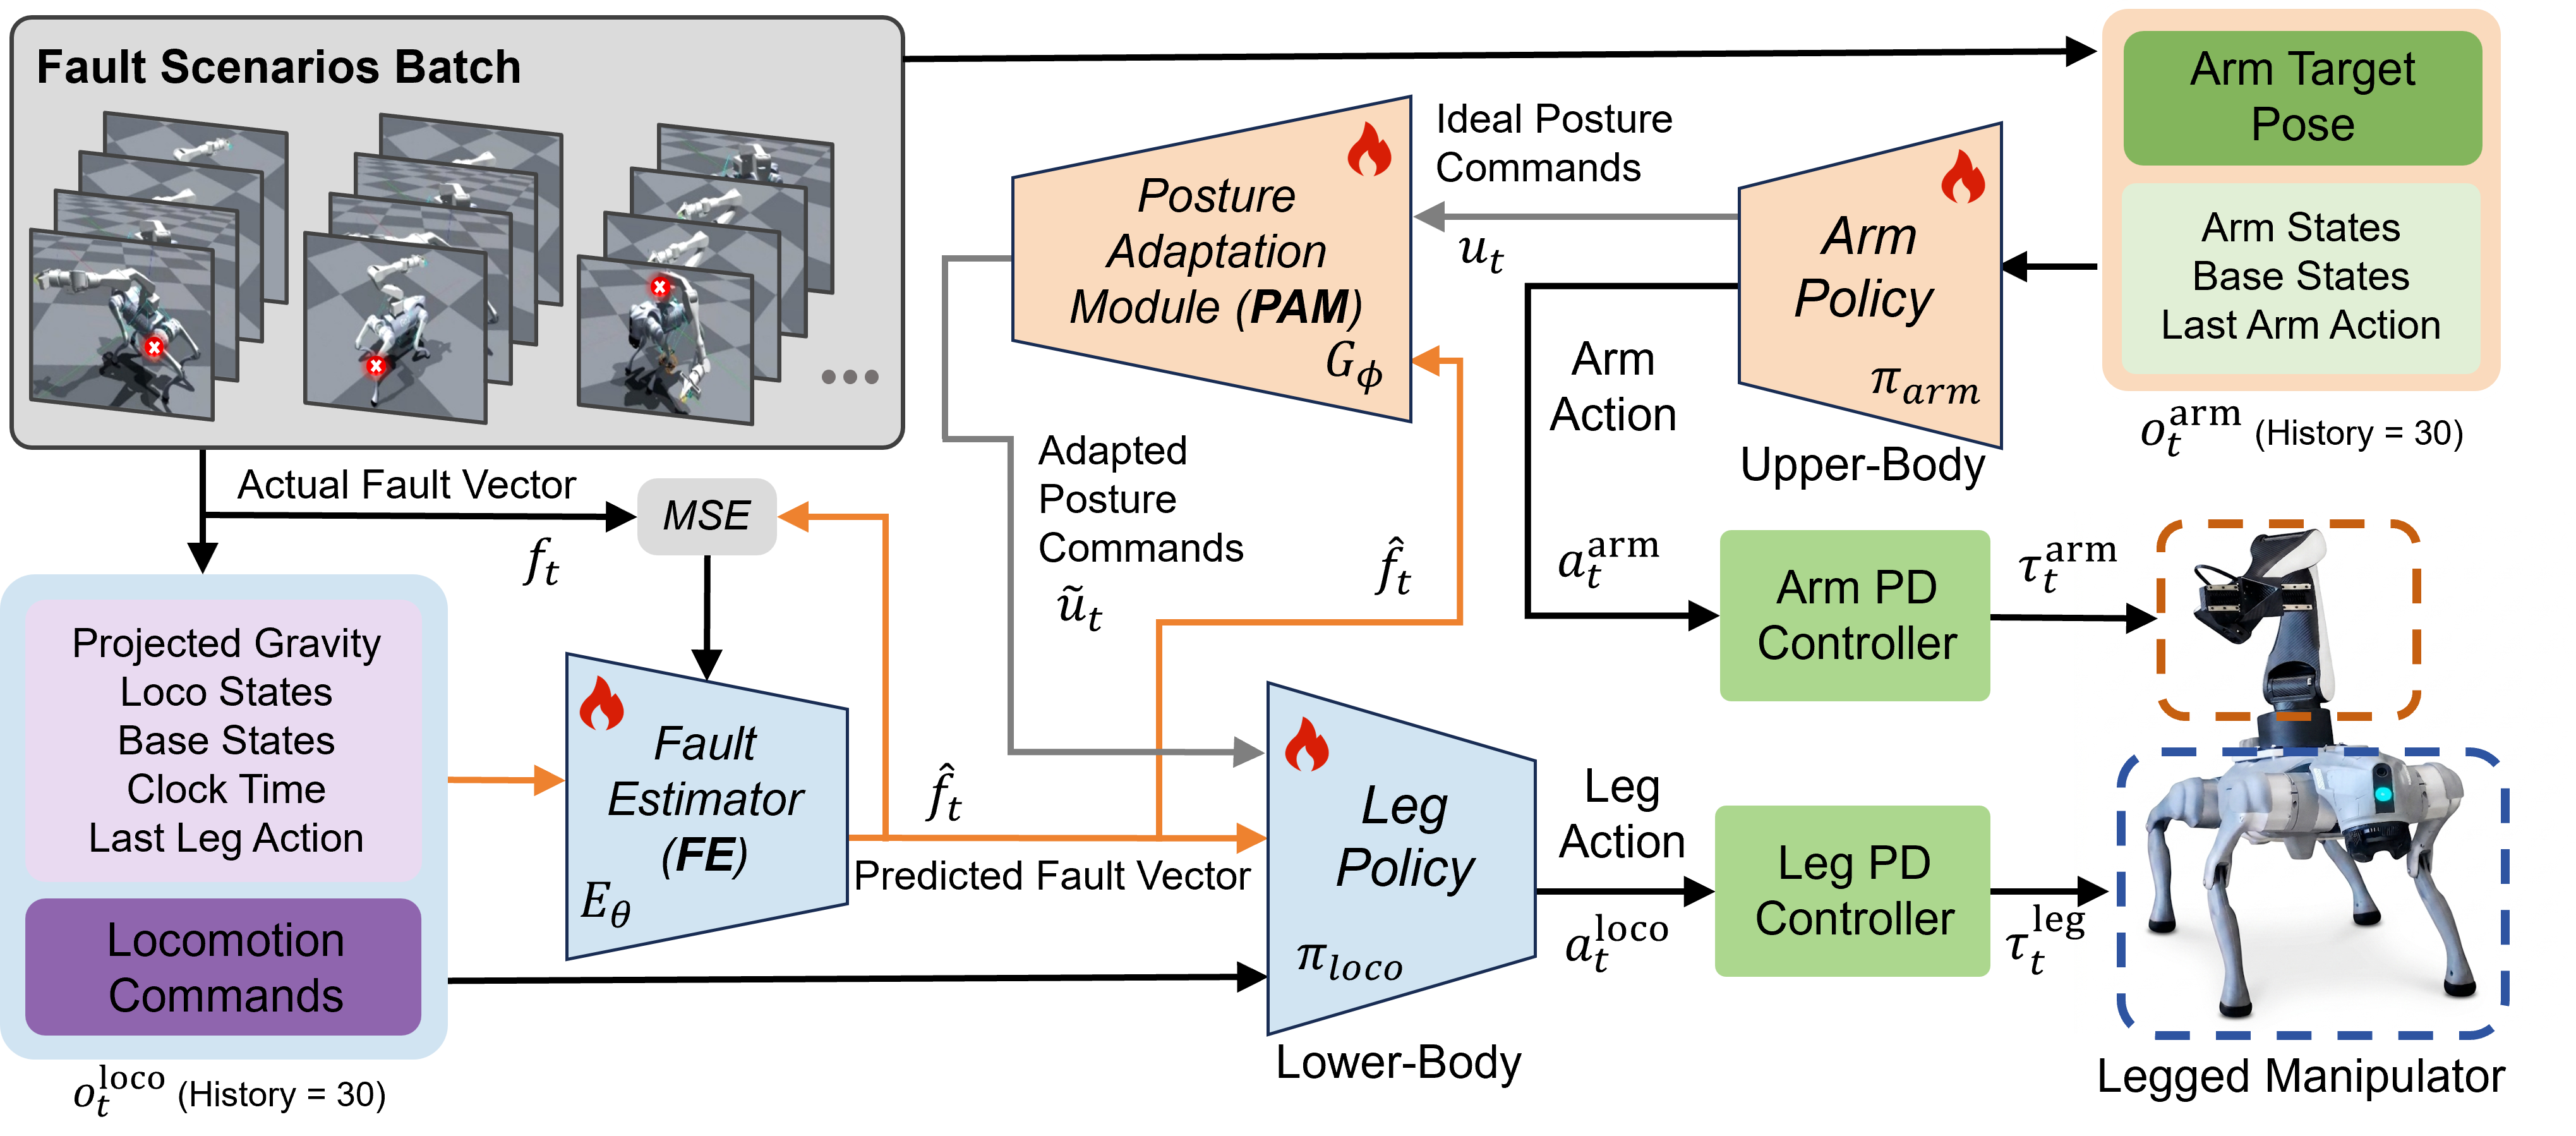
FT-WBC introduces a fault-tolerant loco-manipulation framework that estimates actuator faults and adapts whole-body posture commands to maintain stable behavior under failure conditions.
Framework
Code
Code is coming soon.
Citation
If you find this work useful, please consider citing our paper. Citation information will be updated soon.
Contact
For questions or discussions, please open an issue in this repository.